Multiview recording profiles and task families.
Projects can be scoped across structured task categories with synchronized RGB, depth, and spatial streams where technically feasible.
Recording Profiles
Standardized recording configurations.
Recording configurations can be selected and adapted to task complexity, visibility, sensor requirements, and target model use.
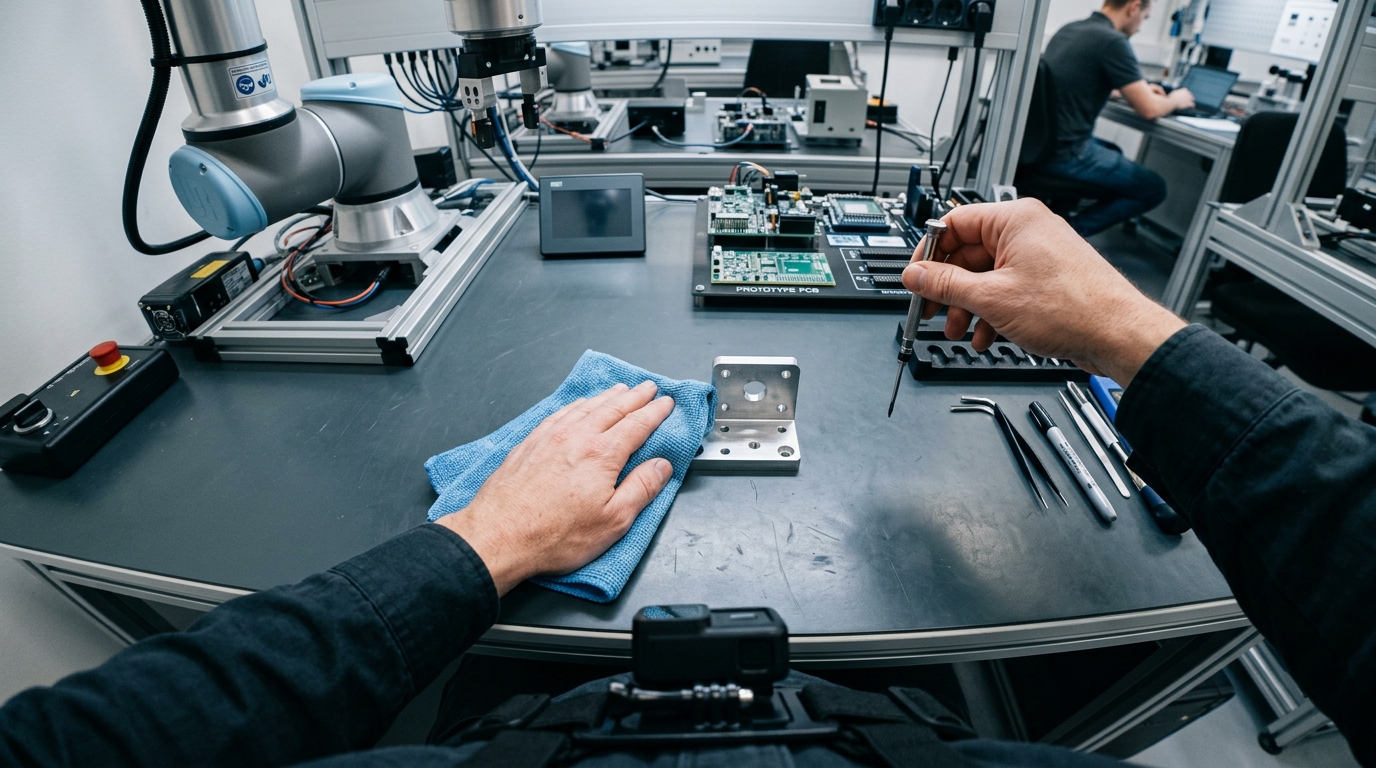
Basic Multiview
Ego / Chest Camera + Static Workspace Camera
A standardized chest-mounted or head-mounted ego camera paired with a single workspace-level camera. Continuous, aligned timeline mapping natural-language instructions to success/failure segment tags.
Specs Preview
- 1080p @ 30 FPS
- Standard RGB sensor
- Natural language instructions
- Start & end states verified
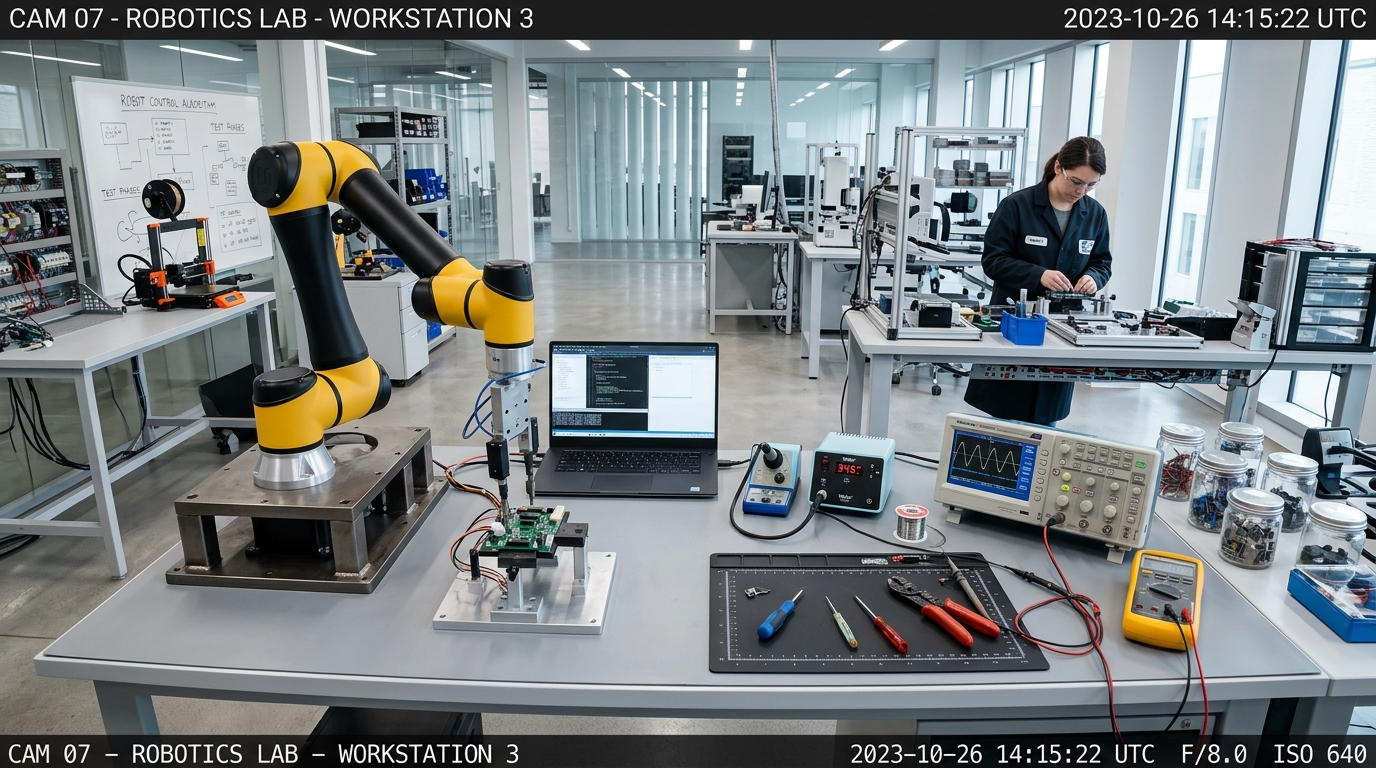
Advanced Multiview
Ego Camera + Front camera + Side camera
Standardized chest camera aligned with dual environmental cameras (front workspace perspective + side overview perspective). Delivers robust coverage of hand-object occlusion, grasp trajectories, and workspace interactions.
Specs Preview
- 1080p @ 30/60 FPS
- Color-calibrated workspace
- Obstruction-free angles
- Unified sync trigger marker
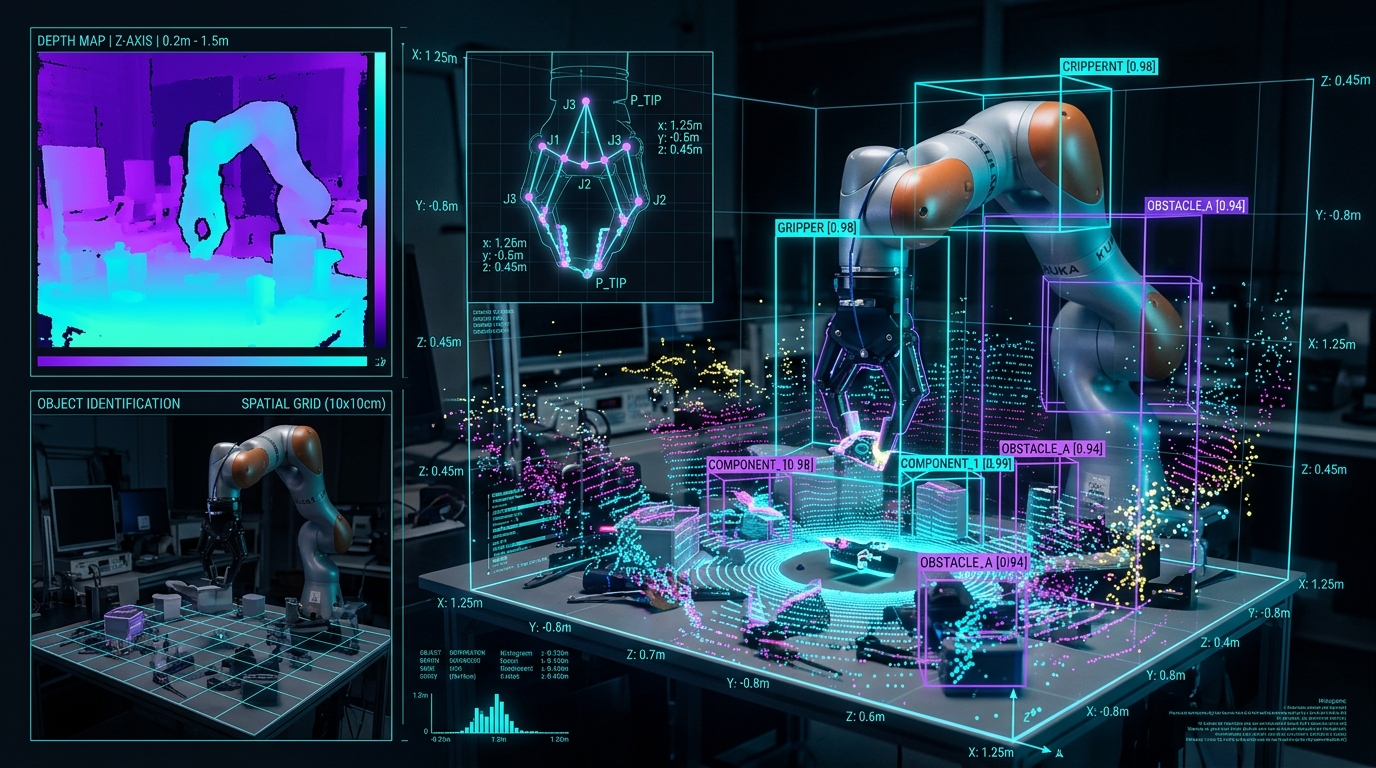
Spatially Enriched
Multiview RGB + Depth + IMU + Calibration (Optional)
RGB-D depth maps, IMU sensor synchronization, camera pose parameters, and 3D hand/object trajectories. Designed for complex manipulation research requiring depth-aligned coordinates.
Specs Preview
- RGB-D depth sync
- IMU sensor alignment
- Camera calibration matrix
- 2D/3D hand keypoints
Task Catalog
Supported task families.
These example task families illustrate structured, low-risk actions that can be assessed for custom data-production projects.
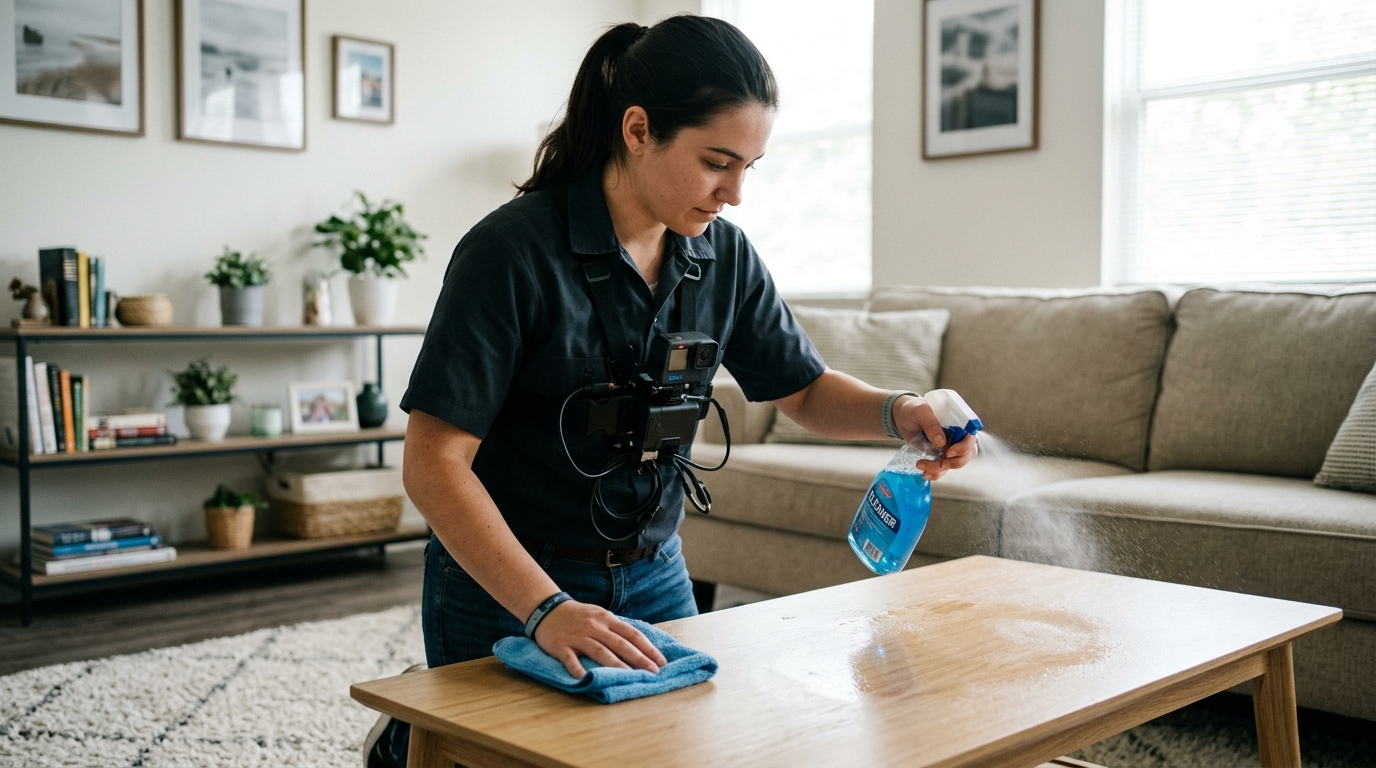
Cleaning and Surface Interaction
- Wipe a surface
- Clear a table
- Simulated spill response
- Pick up loose trash
- Organize cleaning supplies
- Move cleaning tools
- Simulated floor-cleaning pass
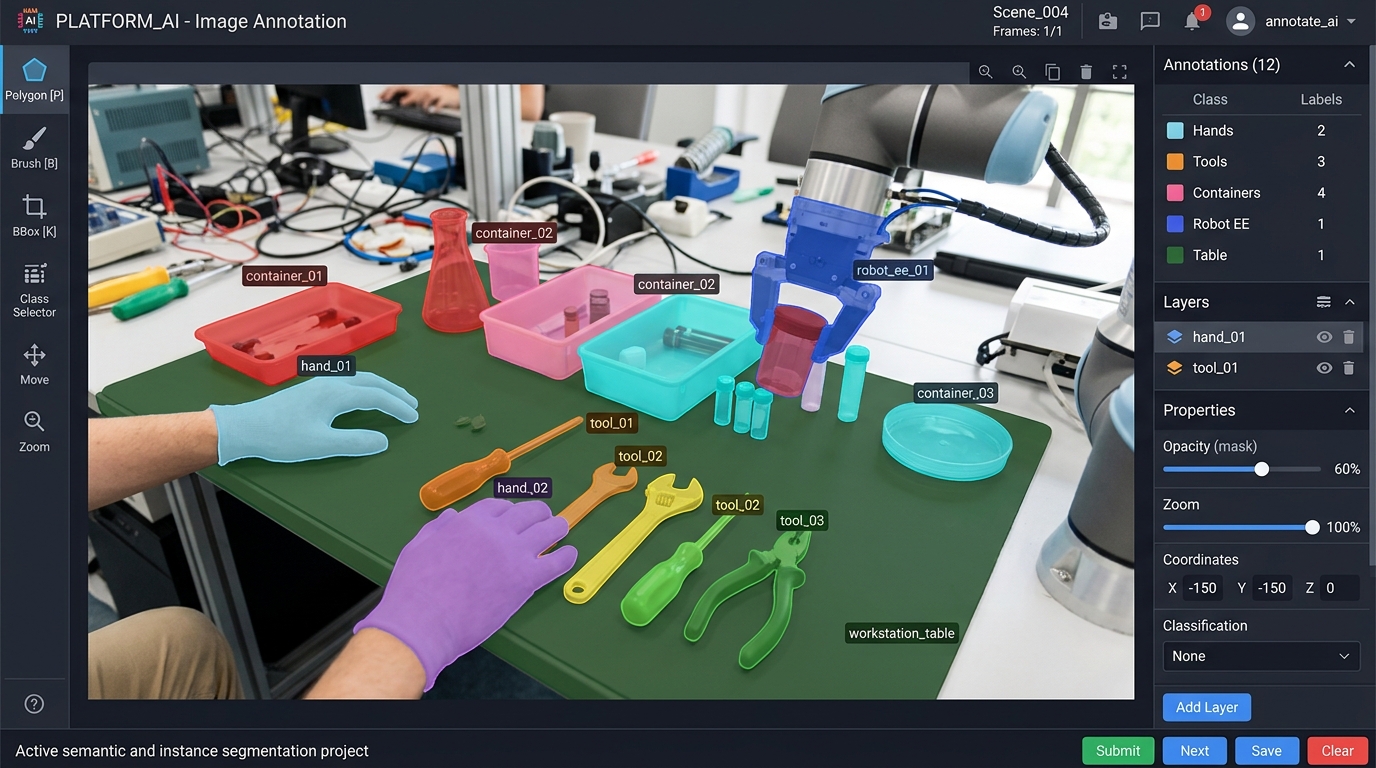
Object Handling & Sorting
- Sort objects into containers
- Group items by category
- Match objects to labeled positions
- Organize objects by size
- Place objects in a defined sequence
- Separate recyclable materials
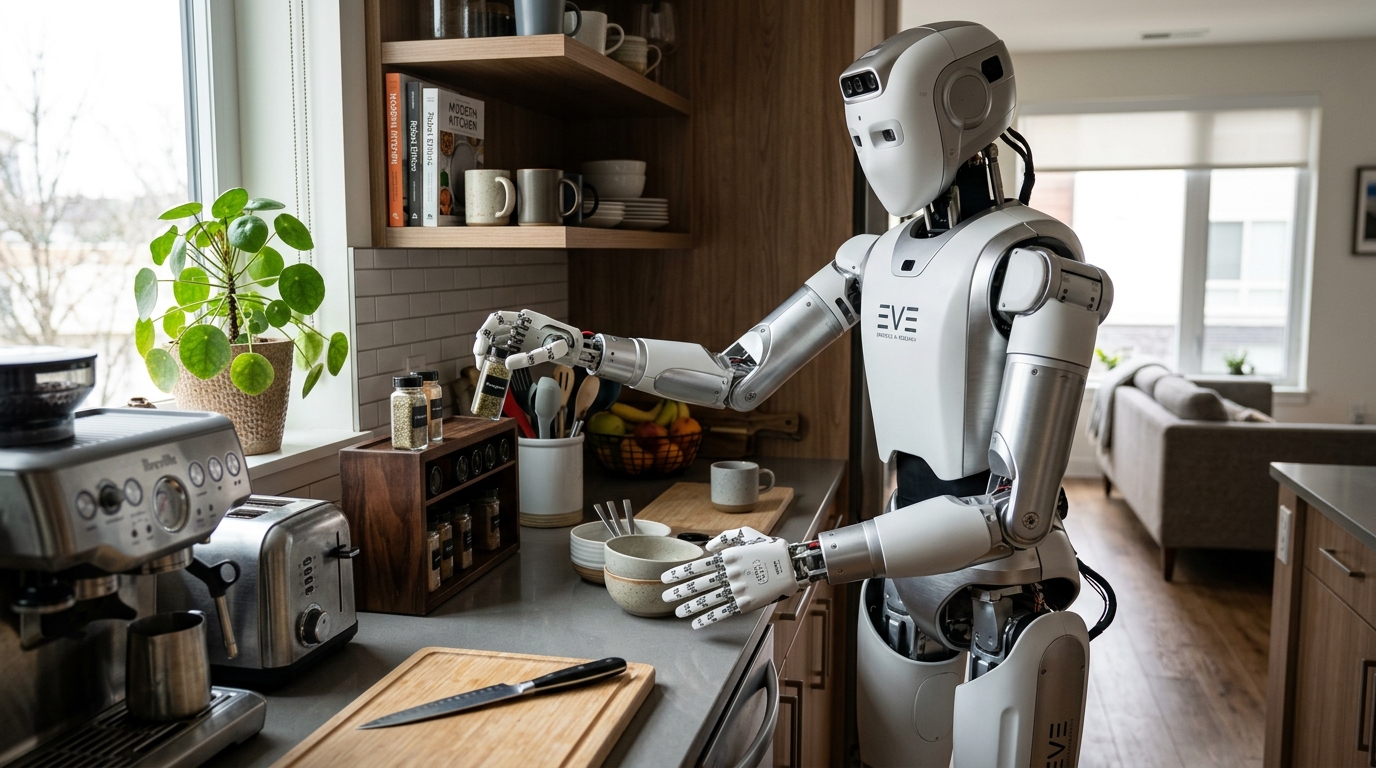
Household & Mock-Apartment Tasks
- Open drawer and place item
- Organize shelf
- Place objects in cabinets
- Fold simple textiles
- Arrange household items
- Clear a workspace
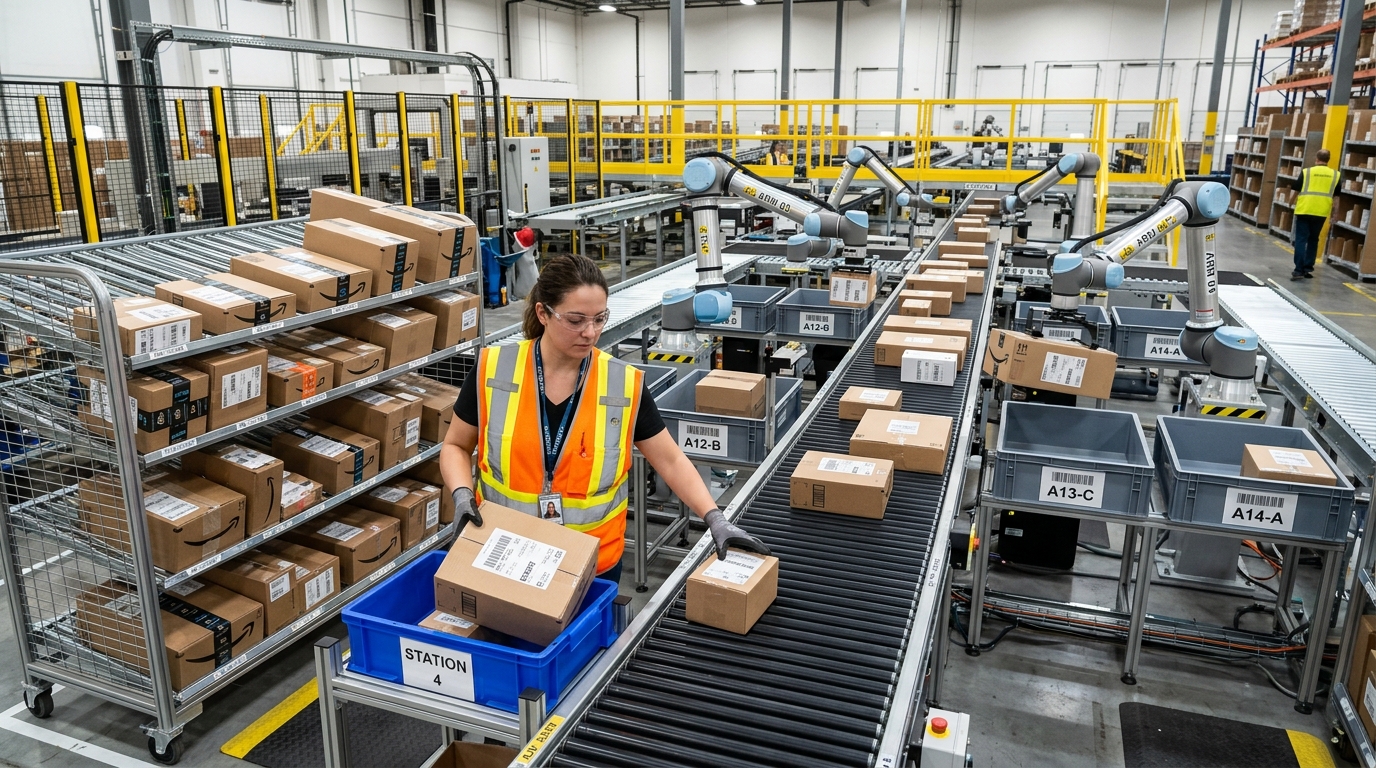
Light Logistics & Handling
- Move parcel from floor to shelf
- Sort lightweight parcels
- Place packages into designated zones
- Load and unload small containers
- Pick and place labeled objects
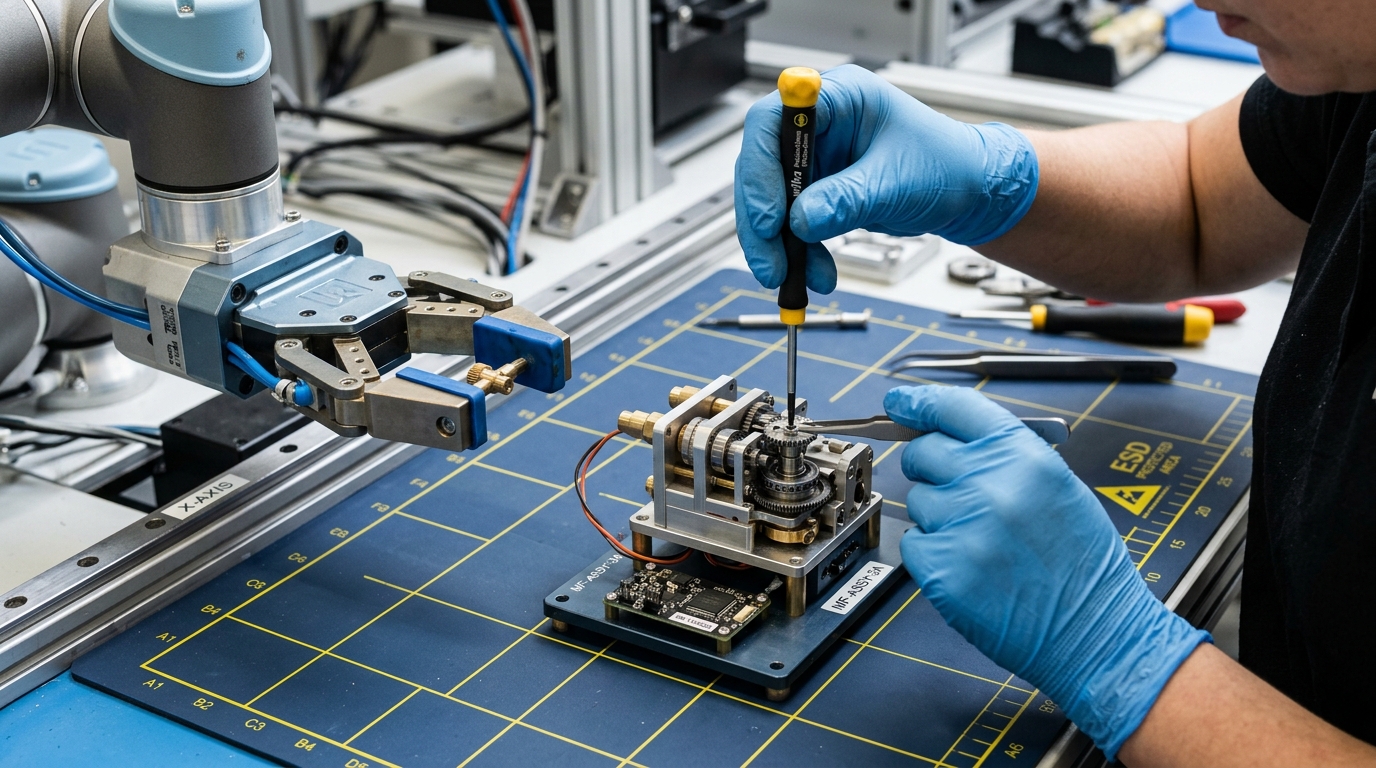
Tool & Assembly Demonstrations
- Select a tool
- Sort tools
- Match screws and components
- Connect non-powered components
- Insert parts
- Assemble simple mock components
- Route cables through holders
- Organize hardware parts
Policy Limits
Direct robot control requires hardware-specific actions.
Human demonstration data focuses on planning, affordance, and temporal segmentation. Direct policy execution on physical systems demands target proprioception.
Explore a customized collection protocol
Contact our engineers to map your task verb ontology to our camera positions.